News
Madrid, May 2020
eProsima announces the general availability of Micro XRCE-DDS 1.2.0. This release introduces the following new features:
- IPv6 support.
- Requester/Replier support.
- Packaging compatibility with colcon.
- Isolated installation option.
- Raspberry Pi support.
But there is more:
The new version also changed the serial transport.
eProsima Micro XRCE-DDS is an open source wire protocol that implements the OMG DDS standard for eXtremly Resource Constrained Environments.
Madrid, May 2020
Automation is the key to the development within the supply chain and logistics sectors, as it has the potential to improve productivity while reducing costs and protecting workers’ health.

Madrid, April 2020
eProsima announces the general availability of eProsima Fast RTPS 1.10.0. This release introduces the following new features:
- New built-in Shared Memory Transport
- Added parameters to fully avoid dynamic allocations
- Transport API refactored to support locator iterators
- Added subscriber API to retrieve info of first non-taken sample
- History of built-in endpoints can be configured
But there is more:
The new version also includes other features, bug fixing and performance improvements.
eProsima Fast RTPS is an open source high-performance publish-subscribe framework to share data in distributed systems using a decoupled model based on Publishers, Subscribers and Data Topics.
Featured
Madrid, March 2020
The DDS security standard includes 5 security modules.
- Authentication plugin
- Access Control plugin
- Cryptographic plugin
- Logging plugin
- Data Tagging
eProsima’s Fast RTPS already includes the Authentication, Access Control and Cryptographic security plugins, and as of ROS 2 Foxy will also include the Logging plugin developed by Canonical. Therefore, Fast RTPS is the most secure open source DDS implementation for ROS 2.
Madrid, March 2020
We are proud to announce that the Robotics Department of the Spanish University Rey Juan Carlos in Madrid chose eProsima Fast RTPS as the DDS implementation to test ROS 2 Navigation 2.

Featured
Madrid, February 2020
 Wind River and eProsima are collaborating to enable ROS (Robot Operating System) on critical applications by extending the platform support of ROS to the Wind River VxWorks real-time operating system (RTOS) and the Linux Foundation’s Zephyr Project. This will allow for the creation of a holistic ROS2 architecture across heterogeneous real-time systems composed of microprocessors running VxWorks and microcontrollers running Zephyr.
Madrid, February 2020
UPDATE 24/02/2020: The participation of eProsima at the Embedded World in Nuremberg is cancelled due to the recent cases of coronavirus in Italy.
eProsima will attend the Embedded World in Nuremberg from the 25th till the 27th of February 2020.
Madrid, February 2020
eProsima will be representing the micro-ROS project together with Bosch, Piap and Fiware at this year’s European Robotics Forum in Malaga from the 3rd till the 5th of March 2020.
Madrid, January 2020
eProsima announces the general availability of eProsima Fast RTPS 1.9.4. This release introduces the following new features:
- Intra-process delivery mechanism is now active by default.
- Synchronous writers are now allowed to send fragments.
- New memory mode DYNAMIC_RESERVE on history pool.
- Performance tests can now be run on Windows and Mac.
But there is more:
The new version includes also bug fixing, and allocation and performance improvements.
eProsima Fast RTPS is an open source high-performance publish-subscribe framework to share data in distributed systems using a decoupled model based on Publishers, Subscribers and Data Topics.
Madrid, November 2019
eProsima announces the general availability of eProsima Fast RTPS 1.9.3. This release introduces the following new features:
- Participant discovery filtering flags.
- Intra-process delivery mechanism opt-in.
But there is more:
The new version includes also bug fixing, and allocation and performance improvements.
eProsima Fast RTPS is an open source high-performance publish-subscribe framework to share data in distributed systems using a decoupled model based on Publishers, Subscribers and Data Topics.
Madrid, November 2019
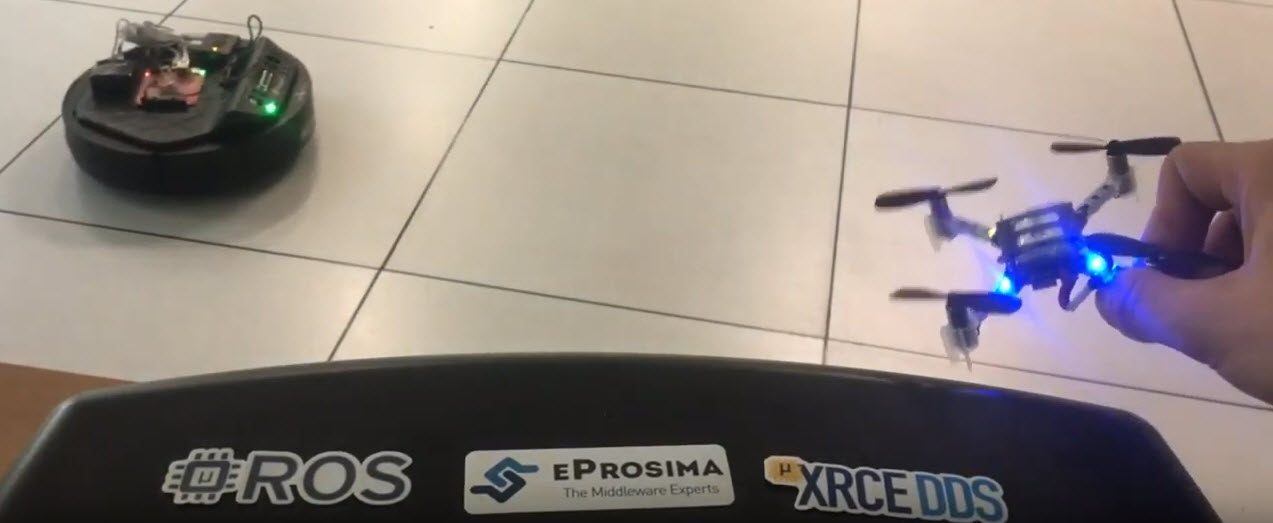
What have a TurtleBot and a Crazyflie in common? Not much, you think?!
Well, eProsima connected them in a very special way, using micro-ROS!
Micro-ROS was presented at the ROSCon in Macau 2019 by Bosch Corporate Research and eProsima and is, simply put, ROS 2 for microcontrollers.
Featured
Madrid, October 2019
eProsima is happy to announce a collaboration with the OTTO Motors division of Clearpath to deploy ROS 2 in systems with a large number of robots.
Madrid, October 2019
eProsima announces the general availability of eProsima Fast RTPS 1.9.2. This release introduces the following new features:
- Multiple initial PDP announcements.
- Flag to avoid builtin multicast.
But there is more:
The new version includes also bug fixing, and allocation and performance improvements.
eProsima Fast RTPS is an open source high-performance publish-subscribe framework to share data in distributed systems using a decoupled model based on Publishers, Subscribers and Data Topics.