Robotics engineering services
Your robot.
Our engineering expertise.
Build, connect and refine your robotic system with the team behind Vulcanexus and Fast DDS. From ROS 2 architecture and platform integration to navigation, human–robot interaction and AI.
Architecture around your requirements.
Hardware and software working together.
Behavior tested on your platform.
 Sensors & control
 Human interaction
 AI applications
 Navigation
Open technology. Engineering tailored to your robot.
Vulcanexus remains an open-source ROS 2 distribution. Choose project-based engineering, a professional subscription, or both.
Robotics services
From individual components to a complete robotic system.
Start with a focused challenge or combine services around your project. Scope, deliverables and validation criteria are agreed before implementation.
- Architecture & performance
- Robot integration
- Navigation & simulation
- Embedded robotics
- Human–robot interaction
- AI for robotics
Typical deliverable
An architecture review, measured findings and a prioritised implementation plan.
Make the communication fit the robot.
Design or review your ROS 2 architecture around the data, network and computing resources of your system. Measure behavior under representative workloads and address the bottlenecks that matter.
- Data interfaces, QoS, discovery and deployment topology.
- Latency, throughput and resource-use analysis.
- Wi-Fi, large sensor data and multi-robot communication.
Typical deliverable
Integrated components, tested interfaces and a documented software baseline.
Bring the components into one working system.
Build on your existing robot or develop a tailored platform. Integrate sensors, actuators and computing with ROS 2 applications, and define the interfaces between the robot and surrounding systems.
- Sensor, actuator and application integration.
- Custom ROS 2 nodes, drivers and protocol adapters.
- Connections to workstations, gateways and remote systems.
Typical deliverable
A configured navigation workflow and reusable simulation and test scenarios.
Develop behavior. Test it in context.
Integrate navigation and simulation into your development workflow. Configure the robot model, sensors and navigation stack around your platform and evaluate behavior in representative scenarios.
- Nav2 integration, localisation and navigation configuration.
- Simulation with Gazebo, Webots or Isaac Sim, as appropriate.
- Repeatable scenarios and checks on the physical platform.
Typical deliverable
An embedded integration tailored to your board, toolchain and communication requirements.
Connect the smallest parts of the robot.
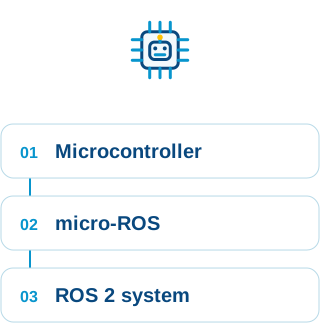
Bring microcontrollers and embedded controllers into your ROS 2 architecture. Scope the hardware, operating system and communication choices to the resources and interfaces available on your target.
- micro-ROS integration and target-platform adaptation.
- Transport, memory and build-system configuration.
- Embedded-to-application communication testing.
Typical deliverable
An integrated interaction pipeline, with behavior evaluated in your intended environment.
Help the robot understand its users.
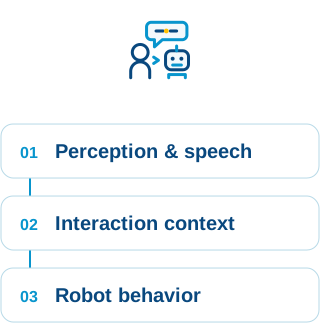
Combine perception and speech into an interaction workflow built around your application. Use Vulcanexus HRI components as a foundation and integrate the behavior your robot needs.
- Face detection and person or pose tracking.
- Speech-to-text and text-to-speech integration.
- Application-specific interaction flows and evaluation.
Typical deliverable
A scoped AI integration with explicit capabilities and an evaluation plan.
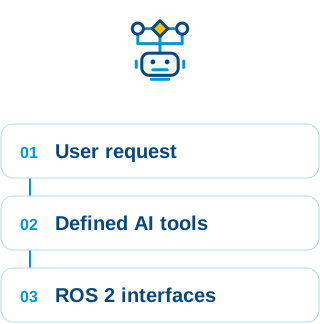
Connect language to defined robot capabilities.
Design or review your ROS 2 architecture around the data, network and computing resources of your system. Measure behavior under representative workloads and address the bottlenecks that matter.
- Data interfaces, QoS, discovery and deployment topology.
- Latency, throughput and resource-use analysis.
- Wi-Fi, large sensor data and multi-robot communication.
Vulcanexus professional subscription
More capability.
Expert support alongside it.
Extend your ROS 2 system with Fast DDS Pro. Replace Fast DDS with its professional edition to gain advanced communication capabilities while remaining fully compatible with ROS 2 and interoperable with other ROS 2 systems.
+
A professional foundation for your ROS 2 system.
- Advanced communication capabilities.
- Professional tools, including DDS Monitor Pro and Discovery Server Pro.
- Unlimited support within the subscription’s agreed scope.
Project-based engineering
Need us to design or build something?
Architecture studies, custom development, robot integration and performance engineering are scoped as separate engagements.
Combine them with a professional subscription when your team needs both implementation work and ongoing product support.
Why eProsima
Robotics expertise.
From the middleware upwards.
Work with engineers who connect the communication foundation with the behavior of the complete robotic application.
The team behind the technology
Draw on our work on Fast DDS, Vulcanexus and micro-ROS to resolve integration challenges with implementation-level knowledge.
Software and platform experience
Connect the embedded controller, the robot computer and the application. Address communication and integration together.

A system you can take forward
Agree the documentation, code, configuration and test evidence your team needs to maintain and evolve the delivered work.
How we work
A clear scope.
A practical engineering outcome.
Work alongside your team, with deliverables and acceptance criteria shaped around your project.
01
Understand
Review the use case, target platform, existing software and constraints.
02
Define
Agree the architecture, work packages, deliverables and validation criteria.
03
Implement
Develop and integrate in focused steps, with reviews alongside your team.
04
Validate & hand over
Test the agreed behavior and transfer the implementation and documentation.
Talk to a robotics expert
What are you building next?
Tell us about your robot, the current stage of development and the challenge you want to solve. We’ll help define the right engineering or subscription path.
Your platform and ROS 2 environment.
Integration, navigation, HRI or AI requirements.
Communication and performance constraints.
Project milestones and expected deliverables.